The MCU block
MicroPythonMCU.MCU is the microcontroller: a package with 8 input/output pins, a ground, a link to a teaching display and an on-board LED. Its behaviour is entirely described by the Python program given by scriptPath. Its reference is the Raspberry Pi Pico (RP2040), whose MicroPython API it reproduces; the icon deliberately reads "MCU".
Connectors
| Connector | Type | Role |
|---|---|---|
GP0 … GP7 |
Electrical pin (PositivePin) |
Each one, at the program's choice: digital input or output (Pin), analog input (ADC), PWM output (PWM), serial line (UART) or I2C bus line (I2C). GP0-GP3 are on the left edge of the icon, GP4-GP7 on the right edge |
GND |
Electrical pin (NegativePin) |
Common reference of all pins. Connect it to the circuit ground (Ground), as on a real board |
Display0 |
Logical link (DisplayLinkOutput) |
To a Peripherals.Display: text sent by machine.Display(0).write(). Not electrical: see LED and display |
The on-board LED (Pin.LED, pin 25 on the Pico) is wired inside the block, with its series resistor: it has no connector. It lights up on the icon, and its current can be plotted under mcu.builtinLed.
Electrical model of a pin
Each GPx pin is a small circuit made of standard electrical components, solved together with the rest of the diagram. The program only controls it.
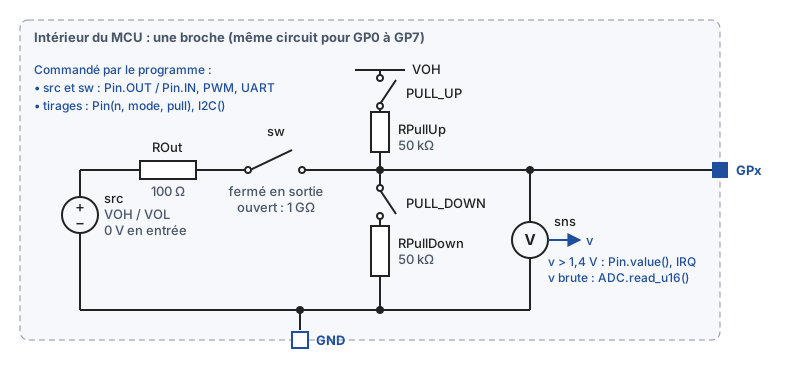
Labels of the diagram, in French: "Intérieur du MCU : une broche" = inside the MCU, one pin (same circuit for GP0 to GP7); "Commandé par le programme" = controlled by the program; "0 V en entrée" = 0 V as an input; "fermé en sortie" = closed as an output; "ouvert" = open; "tirages" = pull resistors; "v brute" = raw voltage.
- Output stage: a voltage source
src(VOHwhen high,VOLwhen low) behind a resistanceROut. The switchswconnects it to the pin when the pin is an output (Pin.OUT,PWM,UARTtransmission). The actual pin voltage depends on what is connected: ≈ 3.07 V with an LED and 330 Ω, for instance. - As an input, the switch is open: the pin is in high impedance. Only a 1 GΩ leakage remains (
GOff): a floating pin ends up at 0 V, and the weakest external resistor is enough to set its level. - Internal pull resistors: two 50 kΩ resistors, one to
VOH(Pin.PULL_UP), the other to ground (Pin.PULL_DOWN), switched on byPin(n, mode, pull). They act whatever the direction.I2C()andI2CTarget()switch on the pull-up of SCL and SDA, as on the Pico;ADC(n)switches off the pulls of its pin. - Reading: a voltage sensor measures the pin at all times, whatever its direction. The program reads 1 above 1.4 V, 0 below: a single threshold,
(VIL + VIH)/2, without hysteresis. TheADCreads the voltage as is, on 16 bits, with a 3.3 V reference.
The pull resistors are controlled conductances rather than switches: 1/50 kΩ when active, 1 pS otherwise. A pin that the program does not use can be left unconnected. At start-up, no pin has a pull resistor. No open-drain mode yet (Pin.OPEN_DRAIN): see the limitations.
Example: Gpio.Pull, two buttons without any external resistor.
Parameters
Double-clicking the MCU opens its parameter dialog. The defaults suit most uses: only the script path needs setting.
Python script
General tab, "Python script" group.
| Parameter | Default | Role |
|---|---|---|
scriptPath |
Resources/Scripts/MCU/demo.py |
Program to run (pick it with the … button). With a file system enabled, it runs after boot.py, instead of main.py; if empty, the flash's main.py runs |
addScriptDirToPath |
true |
Makes the .py files next to the script importable (import my_module), as on the board, where the flash root is on the import path |
libraryPath |
"" |
Optional: any .py file of a shared library folder. Its folder is added to the import path |
A program is therefore split up as on the board: main.py + modules, or an off-the-shelf driver placed next to the program that imports it (examples Program.Imports, I2c.GroveLcd, Weighing.KitchenScale).
Synchronisation
General tab.
| Parameter | Default | Role |
|---|---|---|
tickPeriod |
0.1 s |
Period of the minimal synchronisation point between the program and the circuit: outputs are read back at least at this rate, even if the program never sleeps. The default is fine |
Execution time
Execution time tab.
| Parameter | Default | Role |
|---|---|---|
gpioOpTime |
5e-6 s |
Duration of a pin access (value(), on(), off(), pin(x)), the order of magnitude of MicroPython on an RP2040. Two successive writes without a sleep thus produce a real 5 µs pulse, which enables bit-banging (HX711 driver). 0 makes accesses instantaneous |
Pure Python computation, creating a pin, the ADC, PWM and reading the clock remain instantaneous.
Electrical
Electrical tab. The defaults approximate an RP2040 powered at 3.3 V.
| Parameter | Default | Group | Role |
|---|---|---|---|
VOH |
3.3 V | Logic levels | Output voltage in the high state |
VOL |
0 V | Logic levels | Output voltage in the low state |
VIH |
2.0 V | Logic levels | With VIL, sets the single reading threshold (VIL + VIH)/2 = 1.4 V: above it, an input reads 1 |
VIL |
0.8 V | Logic levels | See VIH: below the threshold, an input reads 0 |
ROut |
100 Ω | Output stages | Series resistance of each output (current the pin can deliver) |
ledSeriesR |
330 Ω | Output stages | Series resistance of the on-board LED |
RPullUp |
50 kΩ | Input stages | Internal pull-up to VOH, switched on by Pin.PULL_UP and by I2C() / I2CTarget() on SCL and SDA |
RPullDown |
50 kΩ | Input stages | Internal pull-down to ground, switched on by Pin.PULL_DOWN |
GOff |
1e-9 S | Input stages | Leakage of a pin that does not drive its line (input, released I2C line), to ground: 1 GΩ |
File system
File system tab, "Simulated flash" group. What the program sees: API, file system.
| Parameter | Default | Role |
|---|---|---|
fsEnabled |
false |
Enables the simulated flash. When disabled, open() and os raise OSError |
fsSource |
"" |
Initial flash image: a folder (data, boot.py, main.py, lib/), given by any of its files, by its path or by a modelica:// URI. Empty: blank flash |
fsWorkspace |
"." |
Folder where each simulation creates its copy of the flash, named <instance>_<FS name>_<date>_<time>. Relative to the simulation folder |
fsOpenExplorer |
true |
Opens Windows Explorer on the copy at the end of the simulation |
The source image is never modified: each simulation starts from a fresh copy, whose path is shown in the log. To chain two simulations, use the copy left by the previous one as fsSource. Example image supplied: Resources/FileSystems/datalogger/ (examples FileSystem.Boot and FileSystem.Script).
Variables to plot
| Variable | Contents |
|---|---|
mcu.GP0.v … mcu.GP7.v |
Voltage of each pin: the signal as an oscilloscope would see it (serial frames, PWM and I2C bus included) |
mcu.GP0.i … |
Current flowing into the pin |
mcu.builtinLed.… |
On-board LED |
mcu.Display0.seq |
Number of messages sent to the display |
Several microcontrollers in a model
A model can hold as many MCU blocks as needed, wired together like real boards: pin to pin (GP of one to GP of the other), through a crossed serial link, or on a shared I2C bus where one is the controller (machine.I2C) and the other a target (machine.I2CTarget). A common ground is still required.
Each microcontroller runs its own program, isolated from the others: its variables, its imported modules (a driver imported by two boards is loaded twice), machine, time and its file system (each one gets its own copy of the flash, even when they start from the same fsSource image). Two boards can therefore run the same file without interfering.
As soon as there are two microcontrollers, every line printed by their print() is prefixed with the instance name in the simulation log ([MyModel.mcuA] ...), as Python-programmable peripherals already do. With a single MCU, the log is unchanged.
Examples: Several microcontrollers.